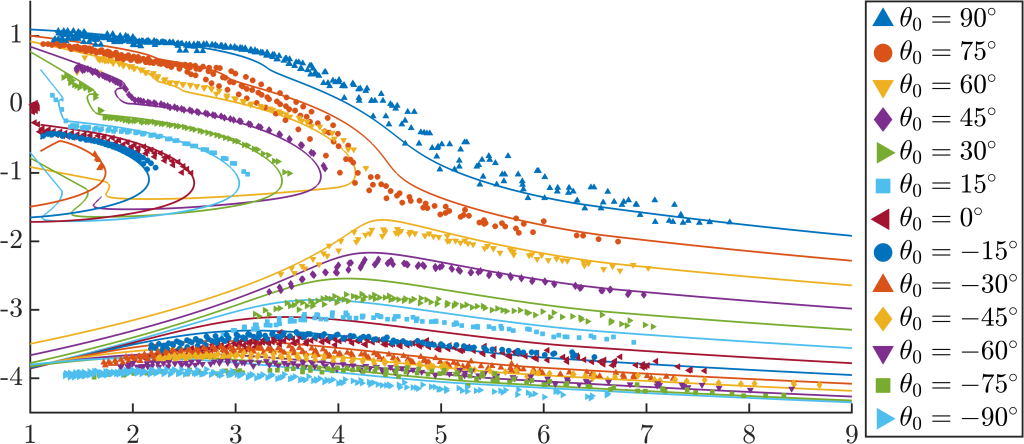
My sophomore year, I worked with Professor Andy Borum studying instabilities in flexible helices. We observe the behavior of a typical desktop Slinky toy. By holding the ends at certain angles and separating them, we can observe a snapping instability where the Slinky quickly shifts between equilibria positions. Using Professor Borum’s Slinky model, I performed numerical simulations with the goal of recreating this experimentally observed bifurcation. As this work has not yet been published, I’ll refrain from giving the entire mathematical model for the slinky, but I will present the following plot.